NanoTorque GSW-600 Reaction Wheels
 GomSpace
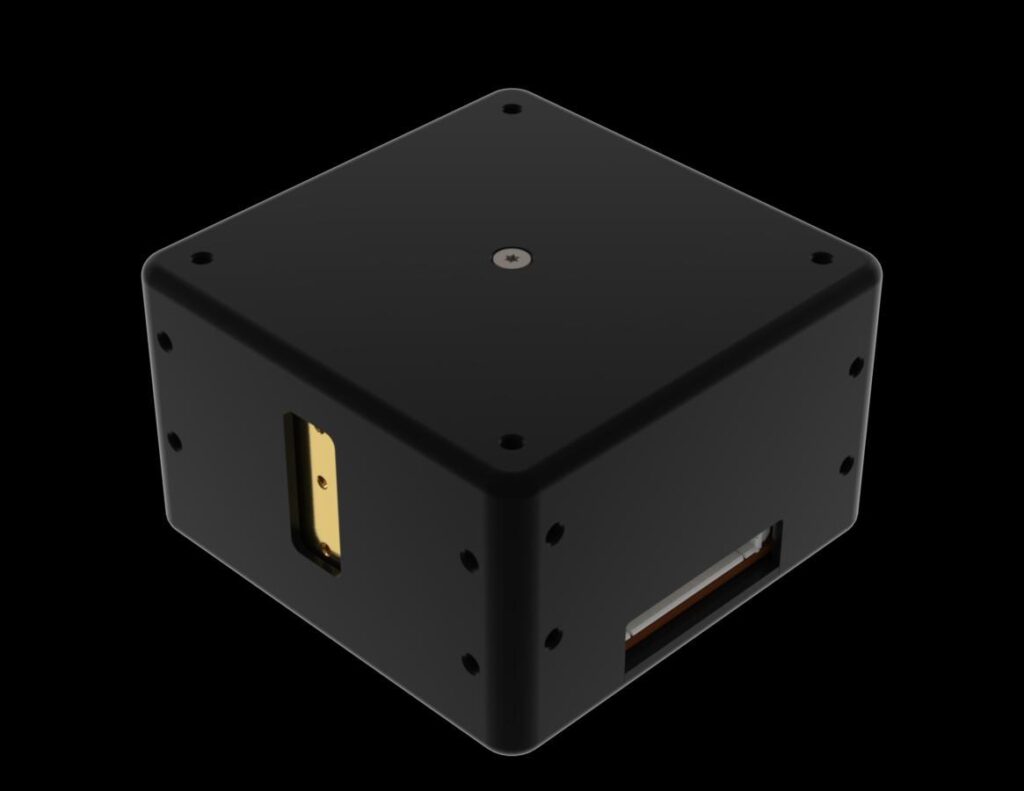
4-wheel pyramid reaction wheel assembly for CubeSats, flight-proven with a 5-year design lifetime and seamless integration with GomSpace ADCS ecosystem.
Typed specifications47 values
Discloses 7 of 10 fields engineers filter by in this category (category median 5).
- Mass
- 180 g One Wheel · datasheet p.8 940 g pyramid: mounting bracket and 4 wheels
- Envelope (L×W×H)
- 44.0 x 44.0 x 27.0 One Wheel · datasheet p.8 95.0 x 95.0 x 61.6 mm pyramid
- Angular momentum storage
- 0.019 N·m·s typ. · At max speed · datasheet p.7 0.019 N·m·s At max speed | 0.019 N·m·s storage
- Max torque
- 2 mN·m datasheet p.4 2 mN·m highlighted features | -1.5 mN·m min · Continuous | -0.015 mN·m min · Minimum torque, Torque control | 0.015 mN·m min · Torque control +2
- Speed range
- -3 500–3 500 rpm min · At max torque · datasheet p.7 -6 000–6 000 rpm min · Maximum | 3 500 rpm max · At max torque | 6 000 rpm max · Maximum | -6 000–6 000 rpm
- Supply voltage
- 5 V nom. · datasheet p.7 4.9 V min | 5.1 V max
- Data interface
- SPI datasheet p.4 I2C
- Operating temperature
- -40 °C min · datasheet p.7 80 °C max | -40–80 °C absolute maximum rating
- Design lifetime
- 3 years design · datasheet p.4 3 years design lifetime | 3 years design, in-orbit operations
- Wheels in the unit
- 4 4-wheel pyramid setup · datasheet p.4 1 single wheel | 4
- Bearing type
- hybrid datasheet p.4 hybrid long life hybrid bearings
- Connector
- Molex PicoBlade right angle, 053261-1371 datasheet p.6 Molex PicoBlade right angle, 053261-1371 Main connector H2
- Survival temperature
- -40 °C min · datasheet p.7 85 °C max
- Flight heritage
- Flight-proven product page
- Satellite class
- CubeSat 6U, 8U and 12U nano-satellites · datasheet p.1
- Drive electronics
- integrated datasheet p.4
- Wheel configuration
- 4 pyramid 4-wheel pyramid setup option · datasheet p.4
- Continuous (nominal) torque
- 1.5 mN·m continuous, -1.5 to 1.5 mNm · datasheet p.7
- Mounting pattern
- 4 x M2 screws, mounting from five out of six sides (single wheel) datasheet p.8
- Flywheel moment of inertia
- 0 kg·m² flywheel inertia 300 gcm2 as printed · datasheet p.8
- Control modes
- torque torque control · datasheet p.7
Each value is typed with its unit and measurement condition and cites the datasheet page it was taken from. Nothing is guessed: a field that is absent here has not been published by the manufacturer. machine-extracted ✓ checked by NewSpace Market ✓ manufacturer confirmed by the manufacturer.
As published by the supplier16 lines, in the manufacturer's own wording
- Configuration
- 4-wheel pyramid assembly
- Design lifetime
- 5 years in-orbit
- Integration
- Compatible with NanoTorque GST-600 magnetorquer
- Application
- CubeSat 3-axis attitude control
- Flight heritage
- Flight-proven
- Mass
- 180 g
- Dimensions
- 44.0 x 44.0 x 27.0 mm
- Torque
- 1.5 mNm
- Minimum torque
- 0.015 mNm
- Momentum
- 19 mNms
- Supply voltage
- 4.9 V
- Supply current
- 500 mA
- Interface
- SPI, I2C
- SPI speed
- 130 kbps
- I2C speed
- 400 kHz
- I/O voltage
- 3.3 V
About
NanoTorque GSW-600 consists of four compact and high-performance reaction wheels, each designed and qualified for an equivalent of 5 years in-orbit operations. The product is delivered in a 4-wheel pyramid setup within a mounting bracket, optimized for three-axis attitude control of CubeSats. The compact envelope allows all four wheels to be installed in a redundant pyramid configuration within the standard CubeSat form factor. NanoTorque GSW-600 is designed for seamless integration with the NanoTorque GST-600 3-axis magnetorquer; together they form GomSpace’s complete attitude determination and control solution for nanosatellites, enabling reliable mission operations for LEO commercial and scientific applications.
Documentation
Need the full ICD, test reports or a specific revision? Ask the supplier directly.