SEPTA36G Solar Array Drive Mechanism
 Beyond Gravity (ex-RUAG Space)
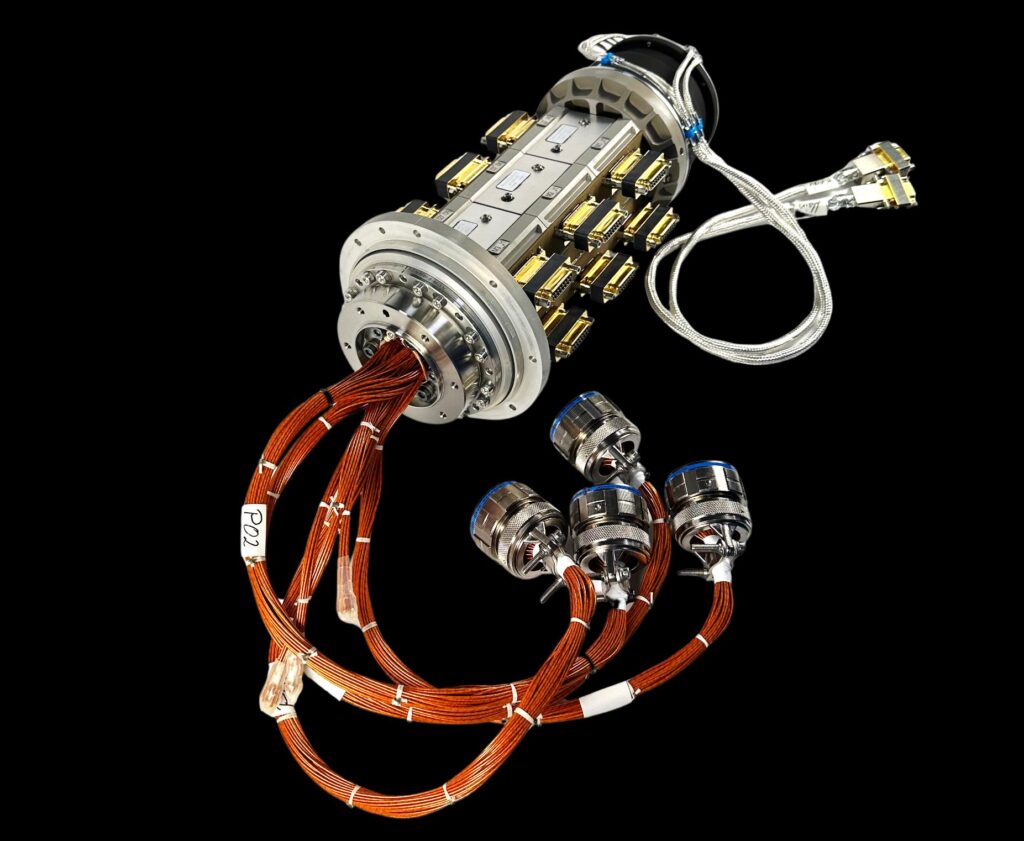
Fully qualified Solar Array Drive Mechanism variant of the modular SEPTA family for demanding missions.
Typed specifications73 values
Discloses 9 of 13 fields engineers filter by in this category (category median 2).
- Mass
- 4 200 g SEPTA36G-1 (excl. customer-specific harness) · datasheet p.4 4 200 g SEPTA36G-1, excl. customer-specific harness | 5 200 g SEPTA36G-2 (excl. customer-specific harness) | 5 200 g SEPTA36G-2, excl. customer-specific harness | 6 200 g SEPTA36G-3 (excl. customer-specific harness) +1
- Slip-ring tracks
- 30 SEPTA36G-1, Number of tracks (all tracks identical and usable… · datasheet p.3 30 SEPTA36G-1; all tracks identical and usable for power or sign… | 60 SEPTA36G-2 (30 lines) | 60 SEPTA36G-2, Number of tracks (all tracks identical and usable… | 90 SEPTA36G-3 (45 lines) +1
- Envelope (L×W×H)
- 144 mm (Max. Outer Diameter mounting flange), 217 mm (Length Overall) SEPTA36G-1 · datasheet p.4 max. outer diameter mounting flange 144 mm; length overall 217 mm SEPTA36G-1 (length from front of flange 177.5 mm) | 144 mm (Max. Outer Diameter mounting flange), 277.0 mm (Length Overall) SEPTA36G-2 | max. outer diameter mounting flange 144 mm; length overall 277.0 mm SEPTA36G-2 (length from front of flange 237.5 mm) | 144 mm (Max. Outer Diameter mounting flange), 337 mm (Length Overall) SEPTA36G-3 +1
- Power transfer
- 9 000 W SEPTA36G-1, Total Power transfer · datasheet p.3 18 000 W SEPTA36G-2, Total Power transfer | 27 000 W SEPTA36G-3, Total Power transfer | 9 000 W total power transfer, SEPTA36G-1; may be increased depending … | 18 000 W total power transfer, SEPTA36G-2 +1
- Output torque
- 7 000 mN·m Unpowered holding torque · datasheet p.3 55 000 mN·m min · Delivered Output Torque @ 200 mA | 55 000 mN·m min · Delivered Output Torque @ 300 mA | 55 000 mN·m max · Powered Holding Torque
- Rotation speed
- 0.167 rpm max · datasheet p.3 0.167 rpm max · max. output speed
- Supply voltage
- 5 V nom. · potentiometer operating voltage · datasheet p.3 120 V Max. voltage across tracks | 2.5 V Position Measurement, Operating Voltage | 2.5–12 V potentiometer operating voltage 2.5V .. 12V | 12 V Position Measurement, Operating Voltage
- Operating temperature
- -35 °C Cold Operational, S/C conductive interface · datasheet p.5 -30 °C Cold Operational, S/C radiative interface | -40 °C Cold start-up limit, S/C conductive interface | -30 °C Cold start-up limit, S/C radiative interface | 80 °C Hot Operational, S/C conductive interface +9
- Design lifetime
- 15 years in orbit · datasheet p.3
- Continuous rotation
- yes continuous rotation in forward and reverse direction · datasheet p.3
- Travel range
- 360 deg continuous rotation in forward and reverse direction · datasheet p.3
- Step size
- 0.006 deg output step size (full step) · datasheet p.3
- Positioning accuracy
- 1 ° position output accuracy (outside of potentiometer dead band) · datasheet p.3
- Holding torque (unpowered)
- 7 000 mN·m unpowered, ~7 Nm (without optional detent break) · datasheet p.3 55 000 mN·m max · powered
- Power and signal transfer
- other slip rings with connectors (brush type not stated) · datasheet p.2
- Current per track
- 5.5 A maximum per individual track ; as-qualified · datasheet p.3 4.8 A max · 4.8 ARMS simultaneously on all tracks | 5.5 A max · maximum per individual track; as-qualified
- Life, revolutions
- 25 903 GEO qualification campaign: revs as sweeps · datasheet p.3 500 qualified lifetime: full revs on ground
- Random vibration
- 14.92 g RMS random vibrations, parallel to mounting plane (X&Z) · datasheet p.4 19.33 g RMS random vibrations, perpendicular to mounting plane (Y)
- Flight heritage
- Qualified for LEO and GEO missions; flight proven slip ring technology; standard actuator with huge flight heritage datasheet p.2
- Satellite class
- GEO datasheet p.2
- Shock qualification
- 2 543 g 1000 Hz, 10000 Hz · datasheet p.5 2 543 g shock input level at 1000 Hz and 10000 Hz, each axis
- Max bending moment
- 420 N·m static bending load (non-simultaneous); axial load 6670 N, ra… · datasheet p.4
- Voltage per track
- 120 V max · datasheet p.3
- Contact resistance
- 140 mΩ max · connector-to-connector resistance at 22 °C, with 250 mm harness · datasheet p.3 28 mΩ max · noise (RMS; per line, i.e. 2 transfers in series)
- Position feedback
- potentiometer position output availability 0° ... 356.5°; max. dead band < … · datasheet p.3
Each value is typed with its unit and measurement condition and cites the datasheet page it was taken from. Nothing is guessed: a field that is absent here has not been published by the manufacturer. machine-extracted ✓ checked by NewSpace Market ✓ manufacturer confirmed by the manufacturer.
As published by the supplier24 lines, in the manufacturer's own wording
- Type
- Solar Array Drive Mechanism (high power class, demanding missions)
- Qualification
- Fully qualified; qualified for LEO and GEO missions
- Slip ring
- Flight proven in-house slip ring technology
- Modularity
- Interfaces remain the same regardless of power class
- Assembly
- Actuator part, slip rings with connectors, customizable solar array connectors, motor and sensor connectors, mounting interface
- Availability
- Rolling stock for short lead times
- Max. output speed
- 1.0 °/s
- Lifetime
- 15 years in orbit
- Unpowered holding torque
- ~7 Nm
- Powered Holding Torque
- max. 55 Nm
- Delivered Output Torque @ 200 mA
- > 55 Nm
- Delivered Output Torque @ 300 mA
- > 55 Nm
- Motor Back-EMF Constant
- 2.33 Vs/rad
- Position Output Accuracy
- ± 1°
- Potentiometer End-to-End Resistance
- 10 kΩ ±10%
- Operating Voltage
- 2.5 V .. 12 V
- Coil Resistance @ 20°C
- 76 Ω ± 10%
- Coil Inductance @ 20°C
- 156 mH ± 20%
- Motor time constant
- 2 ms
- Max. Outer Diameter mounting flange
- 144 mm
- Axial Load
- 6’670 N
- Radial Load
- 4’890 N
- Bending Load
- 420 Nm
- Torsional Load
- >56 Nm
About
Beyond Gravity offers a modular family of Solar Array Drive Mechanisms, to serve a large range of spacecraft. The SEPTA36G is fully qualified and is available at attractive lead times. It is the variant offered for demanding missions within the high-power SADM range.
Modularity for lowest cost: a family of SADM for a large range of missions, standard mechanical interfaces, a standard actuator with huge flight heritage, and rolling stock that enables short lead times and flexibility. Interfaces remain the same regardless of power class, which makes the family ideal for scalable platforms.
Robust and proven: flight proven slip ring technology, a standard actuator with components flying for decades, an enormous database of unit data with family trend and comparisons, and qualification for LEO and GEO missions.
Tailored for you: Beyond Gravity’s engineering expertise allows adaptation for unusual and specific applications, and adapted interfaces, test scope and modifications are feasible on request. The unit comprises an actuator part, slip rings with connectors, customizable solar array connectors, motor and sensor connectors, and a mounting interface.
Documentation
- SEPTA36G_Solar Array Drive Mechanism_Satellites_Datasheet_Feb2025.pdf PDF source: www.beyondgravity.com ↗
Need the full ICD, test reports or a specific revision? Ask the supplier directly.