Reaction Wheels (RW25)
 Serenum Space
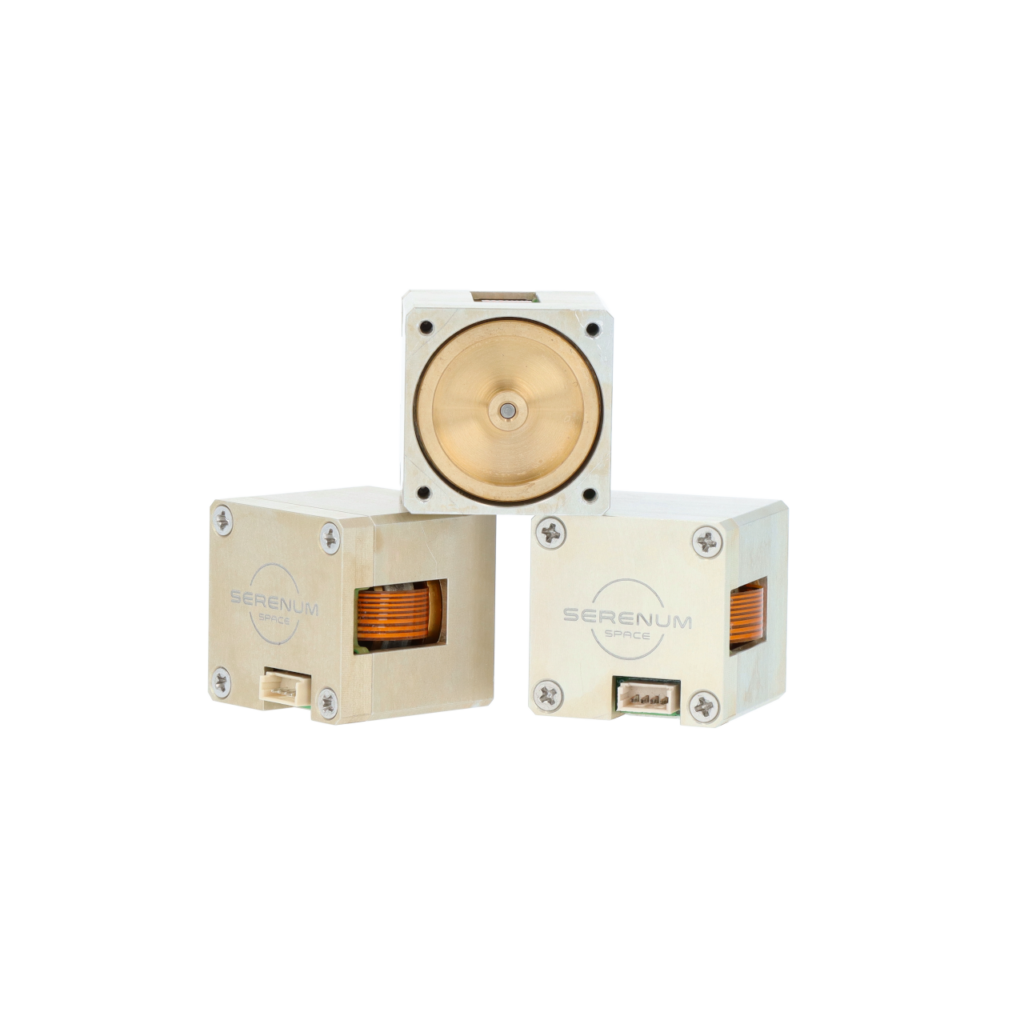
Fine-pointing CubeSat reaction wheels with BLDC motor, integrated IMU, and CubeSat Space Protocol support, for 1U-6U platforms.
Typed specifications12 values
Discloses 4 of 10 fields engineers filter by in this category (category median 5).
- Mass
- 40 g vendor page (catalogue a
- Envelope (L×W×H)
- 25 x 25 x 25 mm product page
- Angular momentum storage
- 0.001 N·m·s product page
- Max torque
- 0.2 mN·m as published, mode unspecified · vendor page (catalogue a
- Supply voltage
- 5–8 V as published, mode unspecified · vendor page (catalogue a
- Power consumption
- 0.3 W typ. · active · vendor page (catalogue a 0.075 W typ. · idle | 0.4 W max · active | 0.1 W max · idle
- Radiation tolerance (TID)
- 36 krad as published, mode unspecified · vendor page (catalogue a
- Static imbalance
- 0.003 g·cm max · product page
- Dynamic imbalance
- 0.006 g·cm² max · product page
Each value is typed with its unit and measurement condition and cites the datasheet page it was taken from. Nothing is guessed: a field that is absent here has not been published by the manufacturer. machine-extracted ✓ checked by NewSpace Market ✓ manufacturer confirmed by the manufacturer.
As published by the supplier17 lines, in the manufacturer's own wording
- Motor
- BLDC with 3 integrated Hall sensors
- Microcontroller
- ARM Cortex-M0+ (24 MHz)
- IMU
- 6-axis (3-axis accelerometer, 3-axis gyroscope)
- Interfaces
- I2C or UART (runtime configurable), CubeSat Space Protocol
- 3.3v rail (absolute max)
- -0.3 to 4.0 V
- Pwr rail (absolute max)
- -0.3 to 11.0 V
- Power consumption idle
- 75 (typ.) / 100 (max) mW
- Power consumption active
- 300 (typ.) / 400 (max) mW
- Mass
- 40 g
- Dimensions
- 25 x 25 x 25 mm
- Radiation tolerance
- 36 krad
- Static imbalance
- < 0.003 g·cm
- Dynamic imbalance
- < 0.006 g·cm
- Speed range
- ± 5600 RPM
- Maximum torque
- 0.200 mN·m
- Total momentum storage
- 0.600 mN·m·s
- Supply voltage variants
- 5 V or 8 V
About
Serenum’s Reaction Wheels combine the capability of performing extremely fine pointing maneuvers, high position accuracy, advanced attitude control including a dedicated freeze mode, low-vibration design, and high energy efficiency, making them ideal for low-GSD Earth observation CubeSat missions on 1U to 6U sized platforms. Each wheel integrates a BLDC motor with three integrated Hall sensors, driven by an ARM Cortex-M0+ microcontroller, and includes a 6-axis inertial measurement unit combining a 3-axis accelerometer and 3-axis gyroscope. Communication is available over I2C or UART, runtime-configurable, with CubeSat Space Protocol support built in. Highlighted features include speed or torque control modes, motor control optimized for low power usage, a fully automatic single-axis freeze mode, and a wide range of self-diagnostic tools such as current/voltage monitoring, configurable software overcurrent protection, automated motor performance evaluation, and in-orbit power consumption optimization. Radiation hardness is improved through ECC non-volatile memory and radiation damage detection across all memory banks. The wheels offer several degrees of sensor redundancy and the possibility to run completely sensorless, are designed to reduce rotating-mass imbalance, and generate low acoustic and mechanical noise, with a low-drift 3-axis gyroscope featuring a built-in high-resolution temperature sensor. The envelope dimensions were chosen so a full three-axis reaction wheel actuator system fits comfortably within a 1U CubeSat, and the wheels are available in 5V or 8V variants.
Documentation
No public datasheet yet — request the datasheet / ICD from the supplier.