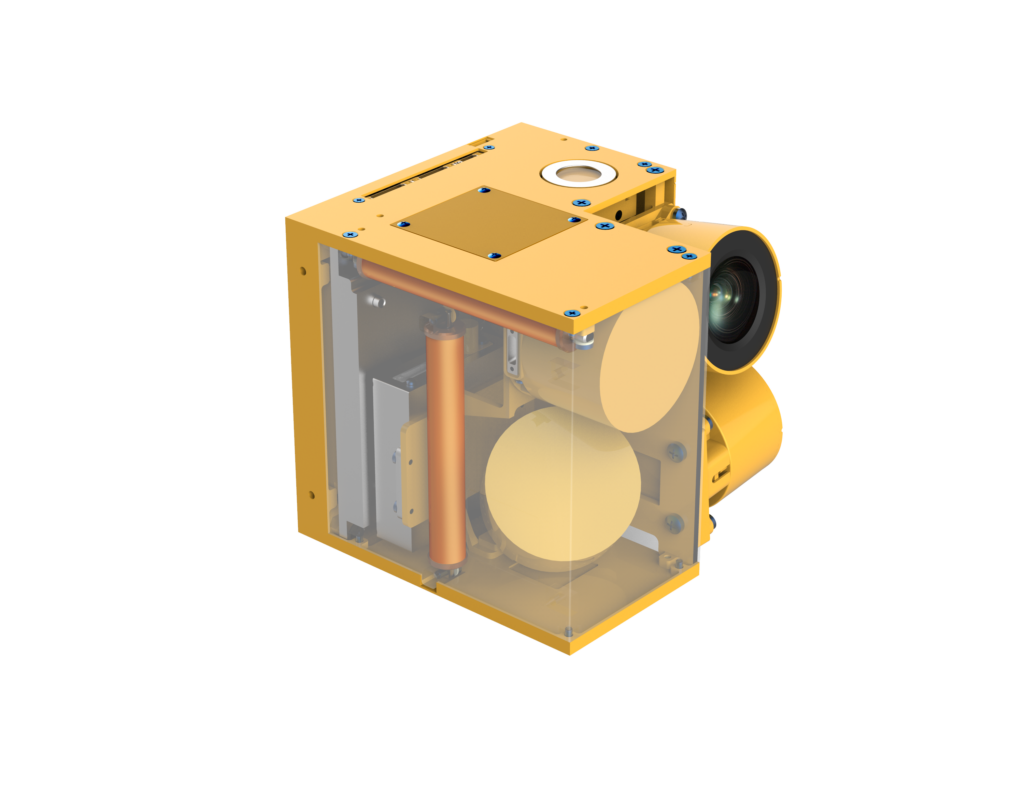
A plug-and-play (PnP) satellite attitude determination and control module (ADCS-N1) integrating star trackers, sun sensor, gyroscope, magnetometer, reaction flywheels, magnetic torquers, and GNSS into one system.
Attitude Control Module PnP ADCS-N1
A plug-and-play (PnP) satellite attitude determination and control module (ADCS-N1) integrating star trackers, sun sensor, gyroscope, magnetometer, reaction flywheels, magnetic torquers, and GNSS into one system.
Description
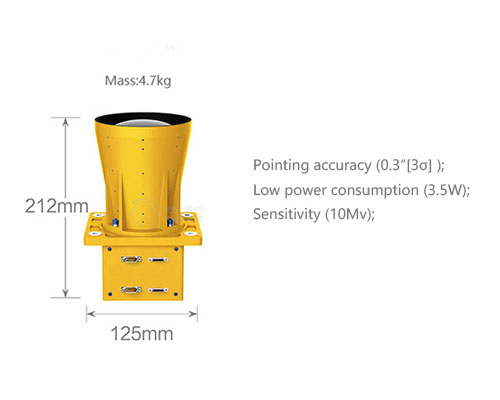
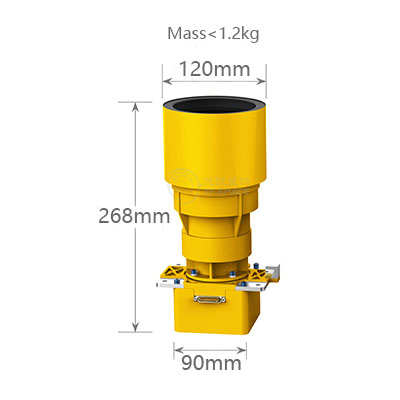
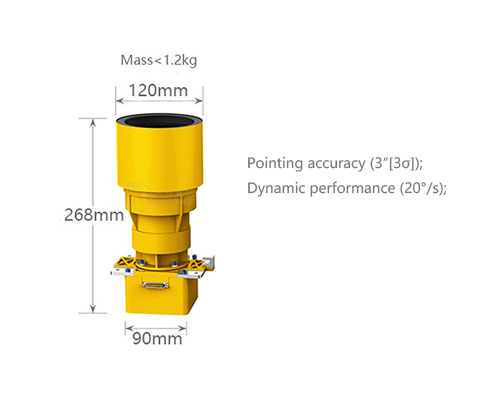
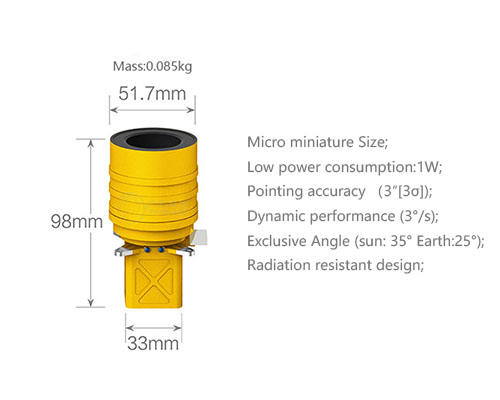
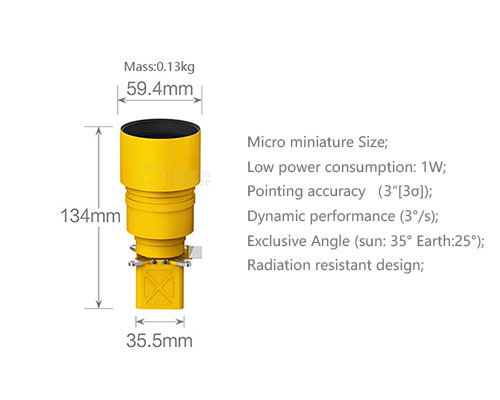
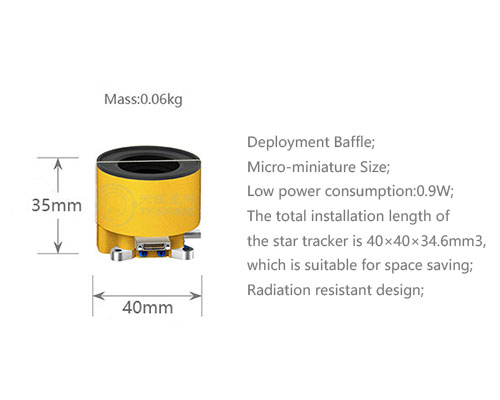
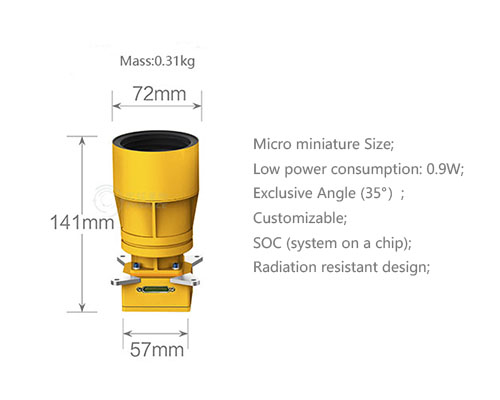
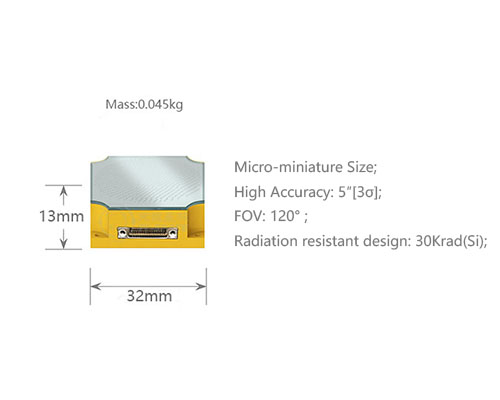
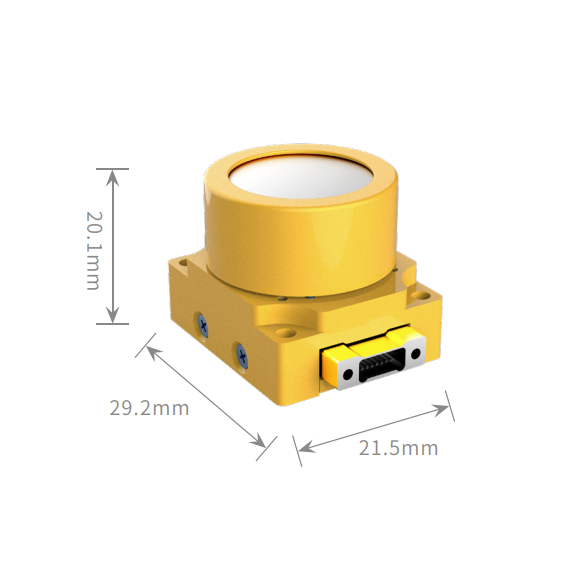
The Attitude Control Module PnP ADCS-N1 is a fully integrated, plug-and-play attitude determination and control system (ADCS) for small satellites, combining a complete suite of sensors and actuators in a single module. It includes 2 star trackers (5 arcsec pointing / 50 arcsec rolling accuracy at 3-sigma, 10 Hz update rate, 2 deg/s dynamic range), a sun sensor (0.1 deg accuracy, 10 Hz, 90x90 deg FOV), a gyroscope (0.5 deg/h zero-bias stability, 0.03 deg/sqrt(h) angle random walk, +/-300 deg/s rate range), a magnetometer (+/-8 Gauss range, +/-1.0% FS linearity error, 10 nT field error), 4 reaction flywheels (20 mNms max angular momentum, 2.5 mNm max torque, 1 rpm speed control accuracy), 3 magnetic torquers (0.82 A*m2 at 12V / 0.34 A*m2 at 5V max magnetic moment), and a GNSS receiver (<=10 m position resolution, <=0.1 m/s velocity accuracy). By packaging attitude sensing, control actuation, and navigation into a single plug-and-play module, the ADCS-N1 simplifies satellite bus integration and provides full 3-axis attitude determination and control capability for small satellite/CubeSat missions.
Specifications
| Star tracker - quantity | 2 |
|---|---|
| Star tracker - accuracy (Pointing/Rolling) | 5" (3sigma) / 50" (3sigma) |
| Star tracker - update rate | 10 Hz |
| Star tracker - dynamic range | 2 deg/s |
| Sun sensor - quantity | 1 |
| Sun sensor - measurement accuracy | 0.1 deg (3sigma) |
| Sun sensor - update rate | 10 Hz |
| Sun sensor - field of view | 90x90 deg |
| Gyroscope - quantity | 1 |
| Gyroscope - zero-bias stability | 0.5 deg/h (Allan variance) |
| Gyroscope - angle random walk | 0.03 deg/sqrt(h) |
| Gyroscope - velocity range measuring | +/-300 deg/s |
| Magnetometer - quantity | 1 |
| Magnetometer - magnetic measuring range | +/-8 Gauss |
| Magnetometer - linearity error | +/-1.0% FS |
| Magnetometer - magnetic field error | 10 nT (1sigma) |
| Reaction flywheel - quantity | 4 |
| Reaction flywheel - max output angular momentum | 20 mNms |
| Reaction flywheel - max output force moment | 2.5 mNm |
| Reaction flywheel - speed control accuracy | 1 rpm |
| Reaction flywheel - force moment control accuracy | 10 nT (1sigma) [as printed on source page] |
| Magnetic torquer - quantity | 3 |
| Magnetic torquer - max output magnetic moment | 0.82 A*m2 (12 V) / 0.34 A*m2 (5 V) |
| GNSS - quantity | 1 |
| GNSS - resolution | <=10 m |
| GNSS - velocity accuracy | <=0.1 m/s |