Model 863 Rotary Actuator
 Moog Space Defense Group
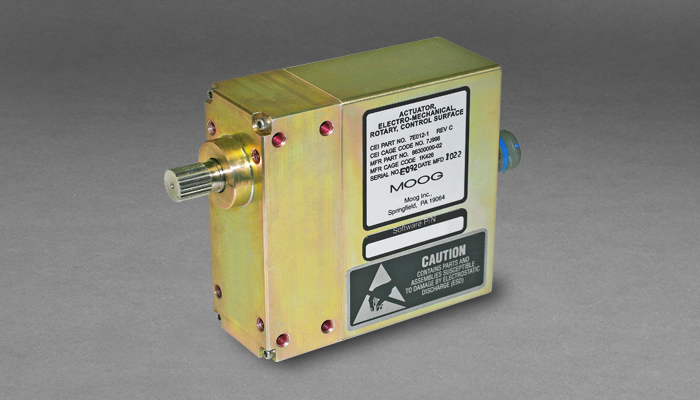
The Model 863 is a high-performance rotary servo electromechanical actuator designed for flight control, throttle control, and other utility functions in UAV and aerospace programs.
Typed specifications41 values
Discloses 6 of 9 fields engineers filter by in this category (category median 2).
- Mass
- 907.18 g max · 2.0 lbm max · datasheet p.3
- Travel range per axis
- -45–45 deg electrical stroke, electronically limited · datasheet p.3 -51.5–51.5 deg mechanical stroke
- Output torque
- 23 726.85 mN·m power point @ 120 deg/sec · datasheet p.3 36 155.2 mN·m max · peak stall torque, electronically limited
- Supply voltage
- 21 V min · Model 86300000-05 · datasheet p.3 18 V min · Model 86300000-40 | 21 V min · Model 86300000-50 | 32 V max · Model 86300000-05 | 32 V max · Model 86300000-40 +3
- Data interface
- RS-485 4 wire RS-485 full duplex, 115.2 Kbaud · datasheet p.3 RS-485 Model 86300000-05 | other Model 86300000-40 | RS-485 Model 86300000-50
- Operating temperature
- -40–71 °C datasheet p.3 -20–70 °C Humidity and Altitude
- Export status
- ITAR falls under the jurisdiction of the ITAR · datasheet p.5
- Mechanism type
- single-axis rotary actuator datasheet p.1
- Axes
- 1 datasheet p.1
- Motor type
- brushless DC (BLDC) rare earth brushless DC motor, brushless permanent magnet · datasheet p.1
- Transmission
- spur or worm gear 4 stage spur gear train assembly · datasheet p.2
- Max payload inertia
- 2.35 kg·m² max · maximum shaft inertia · datasheet p.3
- Backlash
- 21 deg max · with +/-10 in-lbf reversing load applied to shaft · datasheet p.3
- Holding torque (unpowered)
- 3.75 mN·m max · unpowered backdrive torque · datasheet p.3
- Drive electronics
- integrated integrated servo loop control electronics · datasheet p.1
- Random vibration
- 8.27 g RMS captive carry, endurance random, MIL-STD-810G 514.6 Proc IV · datasheet p.2 4.76 g RMS captive carry, functional random | 14 g RMS free flight, boost, 24 sec/axis | 7 g RMS free flight, remainder, 12 min/axis
- Quasi-static load
- 20 g linear acceleration, longitudinal axis (thrust) · datasheet p.2 15 g linear acceleration, vertical and lateral axis
- Shock qualification
- 20 g mechanical shock, 11 ms saw tooth · datasheet p.2 40 g mechanical shock, 6 ms saw tooth | 300 g operating shock - booster separation, 6 pulses, 1 ms
- Slew speed
- 180 °/s No Load Speed @ 28 VDC, nominal · datasheet p.3 120 °/s power point at 210 in-lbf | 180 °/s nom. · no load @ 28 VDC
- Position feedback
- other single film position transducer · datasheet p.2
Each value is typed with its unit and measurement condition and cites the datasheet page it was taken from. Nothing is guessed: a field that is absent here has not been published by the manufacturer. machine-extracted ✓ checked by NewSpace Market ✓ manufacturer confirmed by the manufacturer.
As published by the supplier7 lines, in the manufacturer's own wording
- Operating Voltage
- 18 to 32 VDC
- Operating Temperature Range
- -40° to +71° C
- Operating Altitude Range
- Up to 50,000 ft
- Mechanical Stroke
- ±51.5°
- Electrical Stroke
- ±45.0° - electronically limited
- No Load Speed @ 28 VDC
- 180° / sec, nominal
- Water immersion
- to 3 meters
About
The Model 863 Rotary Servo Actuator is engineered to be submersible up to 3 meters for a maximum of 3 hours, making it suitable for diverse applications including target drones. This high-performance rotary servo electromechanical actuator integrates a rare earth brushless DC motor and servo loop control electronics. The 863 servo is utilized for flight control, throttle control, and other utility functions in UAV and aerospace programs. These actuators are built to operate under extreme environmental conditions and are designed for easy integration into customer systems. Key features include integrated position servo loop control with either analog or digital communications, non-jamming mechanical stops, a 4-stage spur gear train assembly, and a corrosion-protected finish output shaft. It also boasts a brushless permanent magnet motor design, high torque capacity in a small volume, a single film position transducer, and digital telemetry feedback. Electronic stops limit input command, and the signal interface is digital RS-485 electrical protocol, with other signal interfaces available upon factory consultation. A thermal management option is also available for high-altitude applications, and it supports water immersion up to 3 meters.
Documentation
Need the full ICD, test reports or a specific revision? Ask the supplier directly.